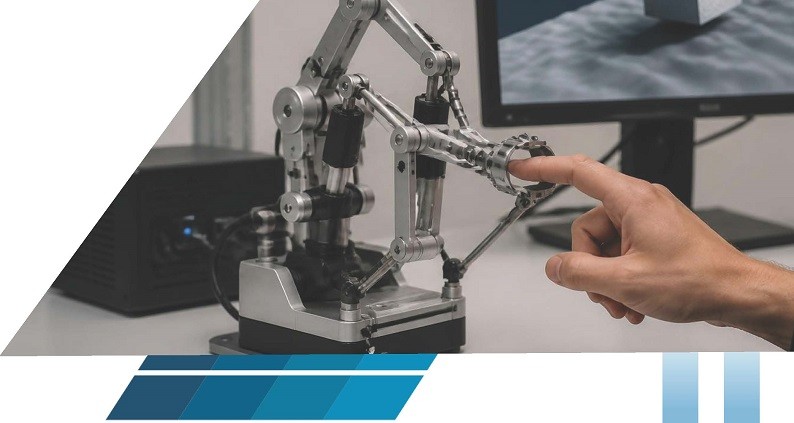

Technical Description
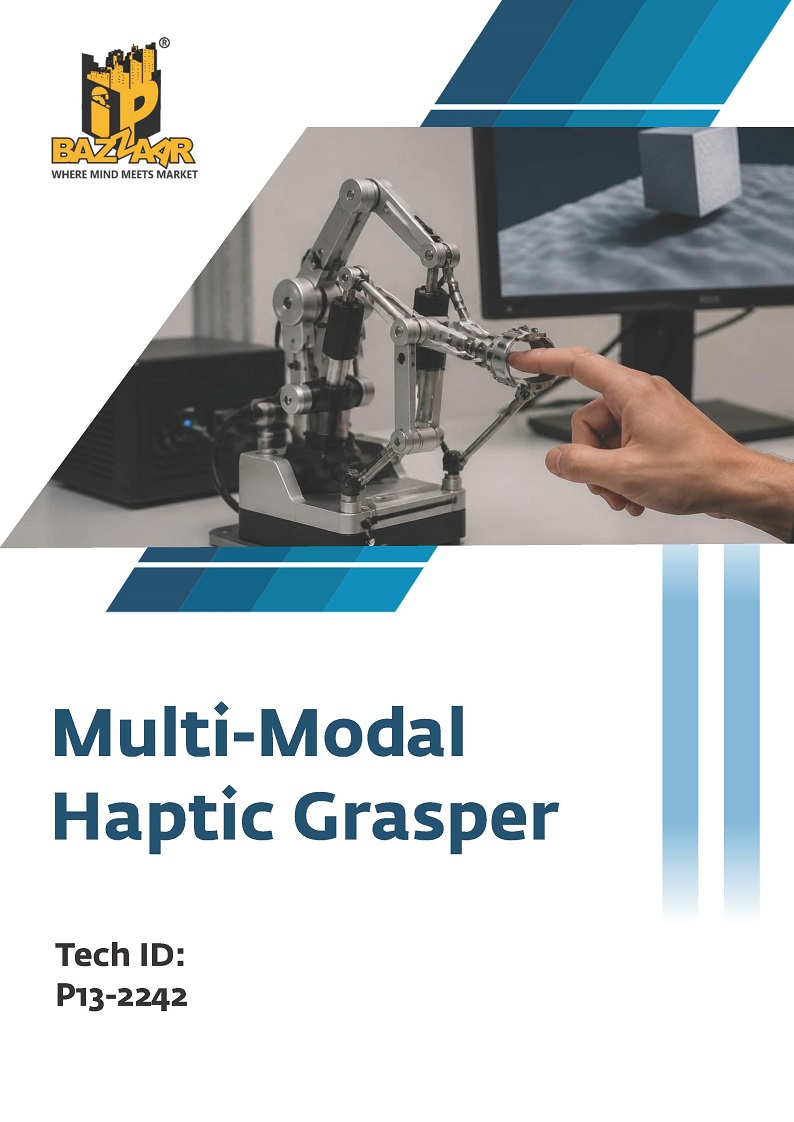
This invention is a three-degrees-of-freedom haptic device that simultaneously renders realistic stiffness, texture, shape, and shear sensations from virtual or remote environments. It utilizes integrated position and impedance control modules to match user finger movements and maximize tactile feedback fidelity.
Problems Addressed
- Lacks Stiffness Rendering
- Excessive System Bulkiness
- High Mechanical Complexity
- Restricted Workspace Dimensions
- Inadequate Resolution Levels
- Reduced Tactile Perception
Tech Features
- Enhanced Haptic Fidelity
- Efficient Multimodal Integration
- Expanded User Workspace
- Adaptive Multi-Finger Support
- Precise 3DOF Feedback
- Optimized Perception Cues
Target Audience
- Healthcare and Medical Sectors
- Defense and Aerospace Industries
- Gaming and Entertainment Sectors
- Rehabilitation and Therapy Industries
- Research & Development
Tech ID: P13-2242 TRL 5 Patent Status: Granted Available For Exclusive and Non-exclusive License